1. Introduction
The space manipulator can replace or assist human beings to perform various space missions and reduce the risks of astronauts to work in the outer space. Owing to this remarkable advantage, the space manipulator has received a great deal of interest with broad potential applications in rendezvous and docking, on-orbit servicing, spacecraft maintenance, and active debris removal [Reference Moosavian and Papadopoulos1–Reference Li, Cheng, Liu, Wang, Shi, Tang, Gao, Zeng, Chai, Luo, Cong and Gao4]. Unlike the ground-based manipulator, the dynamics and control problem of space manipulator are more challenging due to the strong coupling between the spacecraft base and the manipulator. The movements of the manipulator links can have a great effect on the position and attitude motion of the spacecraft base and vice versa. During the last decades, some demonstration experiments about the space robotics have been successfully conducted, such as Robot Technology Experiment (ROTEX) [Reference Hirzinger, Landzettel, Brunner, Fischer, Preusche, Reintsema, Albu-Schäffer, Schreiber and Steinmetz5], Engineering Test Satellite-VII (ETS-VII) [Reference Yoshida6], and Orbital Express (OE). Besides the USA and Europe, China also plans to establish its own on-orbit servicing and maintenance system in the next few years [Reference Li, Cheng, Liu, Wang, Shi, Tang, Gao, Zeng, Chai, Luo, Cong and Gao4].
Generally, the working modes of the space manipulator can be classified into the free-floating mode and free-flying mode [Reference Flores-Abad, Ma, Pham and Ulrich2]. For the attitude-controlled free-flying mode, the rotation of the spacecraft base is actively controlled, leaving the spacecraft base free in translation. When grasping a space target, the space manipulator commonly works in the attitude-controlled free-flying mode to avoid the possible collision hazard between the space manipulator and the target. The trajectory tracking control has always been a significant research issue for space manipulator, which directly determines the successful implementations of the specific space missions. Nevertheless, the dynamic model of the space manipulator is highly nonlinear and strongly coupled. Any motion of the manipulator links can perturb the rotation and translation of the spacecraft base and vice versa. In addition, the space manipulator is inevitably affected by model uncertainties and external disturbances due to the complex space environment. Therefore, the strong robustness is highly required for the space manipulator control system design.
During the last decades, a large quantity of advanced control algorithms have been utilized for the trajectory tracking of space manipulator. Parlaktuna and Ozkan [Reference Parlaktuna and Ozkan7] designed an adaptive control method for the free-floating space manipulator using the dynamically equivalent manipulator model. In [Reference Huang, Xu and Liang8], a dynamic balance control concept was presented for the multi-arm free-floating space manipulator using the proportional–differential (PD) control to drive the joint. Khaloozadeh and Homaeinejad [Reference Khaloozadeh and Homaeinejad9] developed a real-time regulated sliding mode controller for the free-flying space manipulator with multiple manipulators. In [Reference Pazelli, Terra and Siqueira10], various nonlinear H ∞ control methods were designed for the free-floating space manipulator based on the model-based approach and several adaptive approaches including linear parametrization, neural networks, and fuzzy systems. Zhang et al. [Reference Zhang, Ye, Jiang, Zhu, Ji and Hu11] proposed an adaptive output feedback control strategy for the free-floating space manipulator base on the fuzzy neural networks. In [Reference Kumar, Panwar, Borm, Chai and Yoon12], an adaptive neural network-based controller was designed for the free-flying space manipulator with an attitude-controlled base in the presence of parametric uncertainties and external disturbances. Yang et al. [Reference Yang, Yu, Yuan and Fan13] developed a backstepping controller for the flexible space manipulator based on an extended state observer.
More recently, Jayakody et al. [Reference Jayakody, Shi, Katupitiya and Kinkaid14] proposed a robust coordination controller for the space manipulator by applying an adaptive variable structure control method. In [Reference Rybus, Seweryn and Sasiadek15], a new control system that consists of a trajectory planning module and a nonlinear model predictive controller was presented for the free-floating space manipulator. Yu and Chen [Reference Yu and Chen16] proposed an observer-based two-time scale robust control approach for the flexible-joint free-flying space manipulator with external disturbances. In [Reference Shi, Kayastha and Katupitiya17], PD control, sliding mode control, and model predictive control were applied to the robust coordinated control of a dual-arm space manipulator with performance comparisons. Zhu et al. [Reference Zhu, Qiao and Guo18] developed an adaptive sliding mode disturbance observer-based composite controller for the target capturing of space manipulator with prescribed performance. In [Reference Seddaoul and Saaj19], a combined nonlinear H ∞ controller was designed for the free-flying space manipulator subject to inertial uncertainties and environmental perturbations. Zhao et al. [Reference Zhao, Xie, Yang and Liu20] proposed a minimum base disturbance control algorithm for the free-floating space manipulator during visual servoing pre-capturing process. In [Reference Xie, Sun, Kwan and Wu21], a reinforcement learning-based fuzzy adaptive sliding mode controller was presented for the motion control of a space manipulator. Yao [Reference Yao22] proposed several neural adaptive control schemes for the trajectory tracking of space manipulator with output constraints via state and output feedback control. The similar neural adaptive state feedback controller was also employed in [Reference Yao23]. Particularly, the input nonlinearities were considered therein.
Nevertheless, most of the above controllers can only ensure the position and velocity tracking errors regulate to zero or small regions about zero within the infinite settling time. From a practical point of view, it is more desirable for the space manipulator to accomplish the trajectory tracking task in a given time. For example, the dexterous maneuverability is highly required for a space manipulator to capture a moving space target. Distinguishing from the asymptotically stable control, the finite-time control can guarantee the global or practical finite-time stability of the closed-loop system. Until recently, many fruitful results have been reported for the finite-time trajectory tracking control of space manipulator. Yu [Reference Yu24] developed a hybrid-trajectory-based terminal sliding mode controller for a free-flying flexible space manipulator with an elastic base. Jia and Shan [Reference Jia and Shan25] designed a neural network-based adaptive terminal sliding mode controller for the finite-time trajectory tracking of a space manipulator. In [Reference Shao, Sun, Xue and Li26], a nonsingular terminal sliding mode control method was proposed for a free-floating space manipulator with disturbances. However, the settling time of the above finite-time controllers is heavily dependent on the initial states of the system, which to some extent degrade the application value of the finite-time control. To overcome this weakness, the concept of fixed-time control is carried out [Reference Andrieu, Praly and Astolfi27–Reference Zuo30]. The fixed-time control can be viewed as a special case of finite-time control, whose settling time is bounded and the upper bound of the settling time does not rely on the initial conditions of the system states. Owing to this distinctive property, there have been some fixed-time controllers developed for the trajectory tracking of ground-based manipulator currently [Reference Zhao, Kong, Zhang, Li and Fu31–Reference Zhang, Liu, Tang, Hou and Wang35].
Motivated by the aforementioned discussions, in this article, a novel robust fixed-time integrated control approach is presented for the fixed-time trajectory tracking of a free-flying rigid space manipulator perturbed by model uncertainties and external disturbances. The proposed robust fixed-time integrated controller is composed of a nominal fixed-time PD-like controller and a fixed-time disturbance observer. The global fixed-time stability of the whole closed-loop system is strictly proved. In comparisons with the most existing investigations, the main novelties and contributions of this article are twofold. (1) distinguishing from [Reference Zhao, Kong, Zhang, Li and Fu31–Reference Zhang, Liu, Tang, Hou and Wang35], a nominal fixed-time PD-like controller is originally designed by utilizing the bi-limit homogeneous method. The nominal fixed-time PD-like controller can ensure the position and velocity tracking errors regulate to zero in fixed time in the absence of umped disturbance. (2) Then, the robust fixed-time integrated controller is developed by integrating the nominal fixed-time PD-like controller with a fixed-time disturbance observer. The robust fixed-time integrated controller can ensure the position and velocity tracking errors regulate to zero in fixed time even subject to lumped disturbance.
The organization of this article is as follows. Section 2 formulates the problem and gives some preliminaries. Section 3 provides the control design and stability analysis. Section 4 presents the numerical simulations and comparisons. Lastly, Section 5 concludes this research.
2. Problem formulation and preliminaries
2.1. Notations
Throughout this article, the following notations will be used.
 ${\textbf{I}_n}$
denotes the
 $n \times n$
identity matrix,
 ${{\textbf{0}}_n}$
denotes the
 $n \times 1$
column vector with all elements being 0,
 $\left| \cdot \right|$
denotes the absolute value of a real number,
 $\left\| \cdot \right\|$
denotes the Euclidean norm of a vector or the induced norm of a matrix,
 ${\rm{sgn}}(\cdot)$
stands for the signum function, and for given a vector
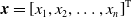 ${\textbf{x}} = {\left[ {{x_1},{x_2}, \ldots ,{x_n}} \right]^{\rm{T}}}$
and a positive scalar
 $\alpha $
,
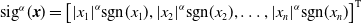 ${\rm{si}}{{\rm{g}}^\alpha }({\textbf{x}}) = {\left[ {{{\left| {{x_1}} \right|}^\alpha }{\rm{sgn}}({{x_1}}),{{\left| {{x_2}} \right|}^\alpha }{\rm{sgn}}({{x_2}}), \ldots ,{{\left| {{x_n}} \right|}^\alpha }{\rm{sgn}}({{x_n}})} \right]^{\rm{T}}}$
and
 ${\mathop{\rm sgn}}({\textbf{x}}) = {\left[ {{\rm{sgn}}({{x_1}}),{\rm{sgn}}({{x_2}}), \ldots ,{\rm{sgn}}({{x_n}})} \right]^{\rm{T}}}$
.
 ${(\cdot)^ \times }$
stands for the skew-symmetric matrix of a vector and for a vector
 ${\textbf{a}} \in {\mathbb {R}^3}$
,
 \begin{align*} {{\textbf{a}}^ \times } = \left[ {\begin{array}{*{20}{c@{\quad}c@{\quad}c}}0 & { - {a_3}} & {{a_2}}\\{{a_3}} & 0 & { - {a_1}}\\{ - {a_2}} & {{a_1}} & 0\end{array}} \right]. \end{align*}
2.2. Dynamics of the space manipulator
Consider an attitude-controlled free-flying space manipulator system composed of a spacecraft base
 ${B_0}$
and
 $N$
manipulator links
 ${B_i}$
(
 $i = 1,2, \ldots ,N$
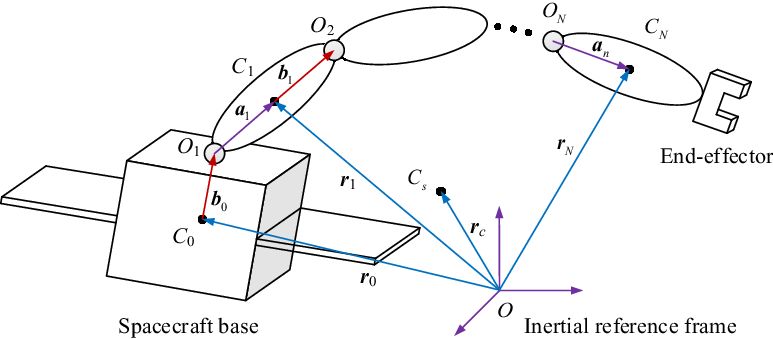
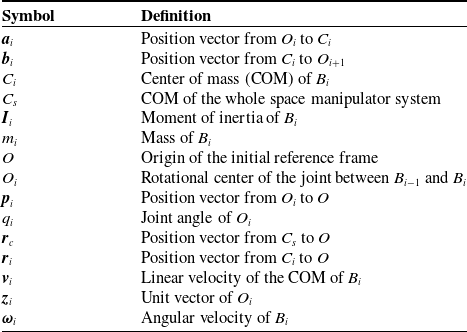
) as illustrated in Fig. 1. The spacecraft base and the manipulator links are all supposed to be rigid bodies. For convenience of the readers, some useful symbols for dynamic modeling are defined in Table I.
Structure of a free-flying space manipulator.

Symbol definitions for dynamic modeling.

According to the relative relations in Fig. 1, the position vector from
 ${C_i}$
to
 $O$
can be expressed as
 \begin{align}{{\textbf{r}}_i} = {{\textbf{r}}_0} + {{\textbf{b}}_0} + \sum\limits_{j = 1}^{i - 1} {\left( {{{\textbf{a}}_j} + {{\textbf{b}}_j}} \right)} + {{\textbf{a}}_i}.\end{align}
The linear velocity of the COM of
 ${B_i}$
can be expressed as
 \begin{align}\begin{array}{l}{{\textbf{v}}_i} = {{\textbf{v}}_0} + {{{\boldsymbol\omega }}_0} \times \left({{{\textbf{r}}_i} - {{\textbf{r}}_0}}\right) + \sum\limits_{j = 1}^i {\left( {{{\textbf{z}}_j} \times \left( {{{\textbf{r}}_i} - {{\textbf{p}}_j}} \right)} \right){{\dot q}_j}} \\\;\;\;\; = \left[ {\begin{array}{*{20}{c@{\quad}c}}{{\textbf{I}_3}} & {{\textbf{r}}_{i0}^ \times }\end{array}} \right]\left[ {\begin{array}{*{20}{c}}{{{\textbf{v}}_0}}\\{{{{\boldsymbol\omega }}_0}}\end{array}} \right] + {{\textbf{J}}_{vi}}{{{\dot{\textbf{q}}}}_m},\end{array}\end{align}
where
 ${{\textbf{r}}_{i0}} = {{\textbf{r}}_0} - {{\textbf{r}}_i}$
,
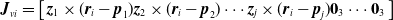 ${{\textbf{J}}_{vi}} = \left[ {\begin{array}{*{20}{l}}{{{\textbf{z}}_1} \times ({{{\textbf{r}}_i} - {{\textbf{p}}_1}})} {{{\textbf{z}}_2} \times ({{{\textbf{r}}_i} - {{\textbf{p}}_2}})} \cdots {{{\textbf{z}}_j} \times ({{{\textbf{r}}_i} - {{\textbf{p}}_j}})} {{\textbf{0}_3}} \cdots {{\textbf{0}_3}}\end{array}} \right]$
, and
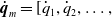 ${{\dot{\textbf{q}}}_m} = [{{\dot q}_1},{{\dot q}_2}, \ldots ,$
 ${{\dot q}_N}]^{\rm{T}}$
. Moreover, the angular velocity of
 ${B_i}$
can be expressed as
 \begin{align}{{{\boldsymbol\omega }}_i} & = {{{\boldsymbol\omega }}_0} + \sum\limits_{j = 1}^i {{{\textbf{z}}_j}{{\dot q}_j}} \nonumber \\ & = {{{\boldsymbol\omega }}_0} + {{\textbf{J}}_{\omega i}}{{{\dot{\textbf{q}}}}_m},\end{align}
where
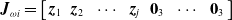 ${{\textbf{J}}_{\omega i}} = \left[ {\begin{array}{*{20}{l}}{{{\textbf{z}}_1}}\;\;\; {{{\textbf{z}}_2}}\;\;\; \cdots\;\;\; {{{\textbf{z}}_j}}\;\;\; {{\textbf{0}_3}}\;\;\; \cdots\;\;\; {{\textbf{0}_3}}\end{array}} \right]$
. When the space manipulator works in the attitude-controlled free-flying mode, the total linear momentum of the space manipulator is conserved. Without loss of generation, suppose that the initial total linear momentum of the space manipulator is equal to zero. Then, we have
 \begin{align}\begin{array}{l}{\textbf{P}} = \sum\limits_{i = 0}^N {{m_i}{{\textbf{v}}_i}} \\[5pt] \;\;\; = \sum\limits_{i = 0}^N {\left( {{m_i}\left[ {\begin{array}{*{20}{c}}{{\textbf{{I}}_3}}\;\;\; {{\textbf{r}}_{i0}^ \times }\end{array}} \right]\left[ {\begin{array}{*{20}{c}}{{{\textbf{v}}_0}}\\[5pt] {{{{\boldsymbol\omega }}_0}}\end{array}} \right] + {m_i}{{\textbf{J}}_{vi}}{{{\dot{\textbf{q}}}}_m}} \right)} \\[5pt] \;\;\; = \left[ {\begin{array}{*{20}{c}}{{m_c}{\textbf{{I}}_3}}\;\;\; {{m_c}{\textbf{r}}_{c0}^ \times }\end{array}} \right]\left[ {\begin{array}{*{20}{c}}{{{\textbf{v}}_0}}\\[8pt] {{{{\boldsymbol\omega }}_0}}\end{array}} \right] + {{\textbf{J}}_{mv}}{{{\dot{\textbf{q}}}}_m}\\[5pt] \;\;\; = {\textbf{0}_3},\end{array}\end{align}
where
 ${m_c} = \sum\limits_{i = 0}^N {{m_i}} $
,
 ${{\textbf{r}}_{c0}} = {{\textbf{r}}_0} - {{\textbf{r}}_c}$
, and
 ${{\textbf{J}}_{mv}} = \sum\limits_{i = 0}^N {{m_i}{{\textbf{J}}_{vi}}} $
. Moreover, the total kinetic energy of the space manipulator can be expressed as
 \begin{align}T = \frac{1}{2}\sum\limits_{i = 0}^N {\left( {{{\boldsymbol\omega }}_i^{\rm{T}}{{\textbf{I}}_i}{{{\boldsymbol\omega }}_i} + {m_i}{\textbf{v}}_i^{\rm{T}}{{\textbf{v}}_i}} \right)} .\end{align}
Substituting (2)–(4) into (5) and rearranging it, we eventually have
 \begin{align}\begin{array}{l}T = \dfrac{1}{2}\left[ {\begin{array}{*{20}{c}}{{{\boldsymbol\omega }}_0^{\rm{T}}}\;\;\; {{\dot{\textbf{q}}}_m^{\rm{T}}}\end{array}} \right]\left[ {\begin{array}{*{20}{c@{\quad}c}}{{{\textbf{M}}_B}} & {{{\textbf{M}}_{BM}}}\\[5pt] * & {{{\textbf{M}}_M}}\end{array}} \right]\left[ {\begin{array}{*{20}{c}}{{{{\boldsymbol\omega }}_0}}\\[5pt] {{{{\dot{\textbf{q}}}}_m}}\end{array}} \right]\\\;\;\; = \dfrac{1}{2}{{{\dot{\textbf{q}}}}^{\rm{T}}}{\textbf{M}}({\textbf{q}}){\dot{\textbf{q}}},\end{array}\end{align}
where the matrices
 ${{\textbf{M}}_B}$
,
 ${{\textbf{M}}_{BM}}$
, and
 ${{\textbf{M}}_M}$
are defined as
 \begin{align}{{\textbf{M}}_B} = \sum\limits_{i = 0}^N {\left( {{{\textbf{I}}_i} + {m_i}{\textbf{r}}_{i0}^{ \times {\rm{T}}}{\textbf{r}}_{i0}^ \times } \right)} - {m_c}{\textbf{r}}_{c0}^{ \times {\rm{T}}}{\textbf{r}}_{c0}^ \times ,\end{align}
 \begin{align}{{\textbf{M}}_{BM}} = \sum\limits_{i = 1}^N {\left( {{{\textbf{I}}_i}{{\textbf{J}}_{\omega i}} + {m_i}{\textbf{r}}_{i0}^ \times {{\textbf{J}}_{vi}}} \right)} - {\textbf{r}}_{c0}^{ \times {\rm{T}}}{{\textbf{J}}_{mv}},\end{align}
 \begin{align}{{\textbf{M}}_M} = \sum\limits_{i = {\rm{1}}}^N {\left( {{\textbf{J}}_{\omega i}^{\rm{T}}{{\textbf{I}}_i}{{\textbf{J}}_{\omega i}} + {m_i}{\textbf{J}}_{vi}^{\rm{T}}{{\textbf{J}}_{vi}}} \right)} - \frac{{{\textbf{J}}_{mv}^{\rm{T}}{{\textbf{J}}_{mv}}}}{{{m_c}}}.\end{align}
Since the space manipulator works in the microgravity environment, the potential energy of the space manipulator can be neglected. Generally, the Lagrangian equation is given as follows:
 \begin{align}\frac{{\rm{d}}}{{{\rm{d}}t}}\left\{ {\frac{{\partial T}}{{\partial {\dot{\textbf{q}}}}}} \right\} - \frac{{\partial T}}{{\partial {\textbf{q}}}} = {\textbf{Q}},\end{align}
where
 ${\textbf{Q}}$
stands for the vector of generalized forces. Substituting (6) into (10), the dynamic model of the space manipulator can be obtained as
 \begin{align}{\textbf{M}}({\textbf{q}}){\ddot{\textbf{q}}} + {\textbf{C}}({{\textbf{q}},{\dot{\textbf{q}}}}){\dot{\textbf{q}}} = {{\boldsymbol\tau }} + {\textbf{d}},\end{align}
where
 ${\textbf{q}} \in {\mathbb {R}^n}$
denotes the generalized position of the space manipulator which includes the attitude of the spacecraft base and the joint angles of the manipulator,
 $n = N + 3$
denotes the total degree-of-freedom of the space manipulator,
 ${\textbf{M}}({\textbf{q}}) \in {\mathbb {R}^{n \times n}}$
denotes the inertia matrix,
 ${\textbf{C}}({{\textbf{q}},{\dot{\textbf{q}}}}) \in {\mathbb {R}^{n \times n}}$
denotes the Coriolis and centrifugal matrix,
 ${{\boldsymbol\tau }} \in {\mathbb {R}^n}$
denotes the control torques, and
 ${\textbf{d}} \in {\mathbb {R}^n}$
denotes the external disturbances. In the presence of model uncertainties, the matrices
 ${\textbf{M}}({\textbf{q}})$
and
 ${\textbf{C}}({{\textbf{q}},{\dot{\textbf{q}}}})$
can be rewritten as
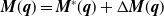 ${\textbf{M}}({\textbf{q}}) = {{\textbf{M}}^ * }({\textbf{q}}) + \Delta {\textbf{M}}({\textbf{q}})$
and
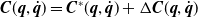 ${\textbf{C}}({{\textbf{q}},{\dot{\textbf{q}}}}) = {{\textbf{C}}^ * }({{\textbf{q}},{\dot{\textbf{q}}}}) + \Delta {\textbf{C}}({{\textbf{q}},{\dot{\textbf{q}}}})$
, where
 ${{\textbf{M}}^ * }({\textbf{q}})$
and
 ${{\textbf{C}}^ * }({{\textbf{q}},{\dot{\textbf{q}}}})$
denote the nominal parts and
 $\Delta {\textbf{M}}({\textbf{q}})$
and
 $\Delta {\textbf{C}}({{\textbf{q}},{\dot{\textbf{q}}}})$
denote the unknown parts, respectively.
Let
 ${\textbf{v}} = {\dot{\textbf{q}}}$
. Subsequently, the dynamic model of the space manipulator can be rearranged as
 \begin{align}\left\{ \begin{array}{l}{\dot{\textbf{q}}} = {\textbf{v}},\\[5pt] {\dot{\textbf{v}}} = - {{\textbf{M}}^{ * - 1}}({\textbf{q}}){{\textbf{C}}^ * }({{\textbf{q}},{\dot{\textbf{q}}}}){\dot{\textbf{q}}} + {{\textbf{M}}^{ * - 1}}({\textbf{q}}){{\boldsymbol\tau }} + {{\boldsymbol\delta }},\end{array} \right.\end{align}
where
 ${{\boldsymbol\delta }} \in {\mathbb {R}^n}$
denotes the lumped disturbance including model uncertainties and external disturbances, which is given as
 \begin{align}{{\boldsymbol\delta }} = {{\textbf{M}}^{ * - 1}}({\textbf{q}})\left( { - \Delta {\textbf{M}}({\textbf{q}}){\ddot{\textbf{q}}} - \Delta {\textbf{C}}({{\textbf{q}},{\dot{\textbf{q}}}}){\dot{\textbf{q}}} + {\textbf{d}}} \right).\end{align}
2.3. Control objective
Let
 ${{\textbf{q}}_{\rm{d}}}$
be the desired position of the space manipulator. Define the position and velocity tracking errors
 ${{\textbf{q}}_e} = {\textbf{q}} - {{\textbf{q}}_{\rm{d}}}$
and
 ${{\textbf{v}}_e} = {\textbf{v}} - {{\dot{\textbf{q}}}_{\rm{d}}}$
. The main goal of this research is to design a suitable controller
 ${{\boldsymbol\tau }}$
for the space manipulator such that the position and velocity tracking errors
 ${{\textbf{q}}_e}$
and
 ${{\textbf{v}}_e}$
can regulate to zero in fixed time even subject to model uncertainties and external disturbances. Before proceeding, the following assumption is made.
Assumption 1. The time derivative of the lumped disturbance is bounded. There exists an unknown positive constant
 $b$
such that
 $\left\| {{\dot{\boldsymbol\delta }}} \right\| \le b$
.
2.4. Useful definitions and lemmas
The following definitions and lemmas are given which will be used in the control design and stability analysis.
Definition 1. [Reference Polyakov29] Consider the nonlinear system:
 \begin{align}{\dot{\textbf{x}}}(t) = {\textbf{f}}({{\textbf{x}}(t)}),\;{\textbf{x}}({{t_0}}) = {{\textbf{x}}_0},\;{\textbf{x}} \in {\mathbb {R}^n},\end{align}
where
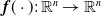 ${\textbf{f}}(\cdot):\;{\mathbb {R}^n} \to {\mathbb {R}^n}$
is a possibly discontinuous vector field. System (14) is said to be globally fixed-time stable if it is globally finite-time stable and the settling time function
 $T({{{\textbf{x}}_0}})$
is bounded, that is, there exists a positive constant
 ${T_{\rm{m}}}$
such that
 $T({{{\textbf{x}}_0}}) \le {T_{\rm{m}}}$
,
 $\forall {{\textbf{x}}_0} \in {\mathbb {R}^n}$
.
Definition 2. [Reference Andrieu, Praly and Astolfi27] For
 $p = 0$
or
 $p = \infty $
, a function
 $f({\textbf{x}})$
is said to be homogeneous in the p-limit with associated triple
 $({{{\textbf{r}}_p},{d_p},{f_p}({\textbf{x}})})$
, where
 ${{\textbf{r}}_p}$
is the weight,
 ${d_p}$
is the degree, and
 ${f_p}({\textbf{x}})$
is the approximating function, if for each compact set
 $C \in {\mathbb {R}^n}$
,
 \begin{align}\mathop {\lim }\limits_{\varepsilon \to p} \mathop {\max }\limits_{{\textbf{x}} \in C} \left( {\frac{{f\left( {{\varepsilon ^{{r_{p,1}}}}{x_1}, \ldots ,{\varepsilon ^{{r_{p,n}}}}{x_n}} \right)}}{{{\varepsilon ^{{d_p}}}}} - {f_p}({\textbf{x}})} \right) = 0.\end{align}
A vector field
 ${\textbf{f}}({\textbf{x}}) = {\left[ {{f_1}({\textbf{x}}), \ldots ,{f_n}({\textbf{x}})} \right]^{\rm{T}}}$
is said to be homogeneous in the p-limit with associated triple
 $({{{\textbf{r}}_p},{d_p},{{\textbf{f}}_p}({\textbf{x}})})$
, where
 ${{\textbf{r}}_p}$
is the weight,
 ${d_p}$
is the degree, and
 ${{\textbf{f}}_p}({\textbf{x}}) = {\left[ {{f_{p,1}}({\textbf{x}}), \ldots ,{f_{p,n}}({\textbf{x}})} \right]^{\rm{T}}}$
is the approximating vector field, if the function
 ${f_i}({\textbf{x}})$
is homogeneous in the p-limit with associated triple
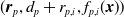 $({{{\textbf{r}}_p},{d_p} + {r_{p,i}},{f_{p,i}}({\textbf{x}})})$
.
Definition 3. [Reference Andrieu, Praly and Astolfi27] The vector field
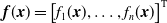 ${\textbf{f}}({\textbf{x}}) = {\left[ {{f_1}({\textbf{x}}), \ldots ,{f_n}({\textbf{x}})} \right]^{\rm{T}}}$
is said to be homogeneous in the bi-limit if it is homogeneous in the 0-limit and in the ∞-limit simultaneously.
Lemma 1. [Reference Andrieu, Praly and Astolfi27] Consider system (14). If the vector field
 ${\textbf{f}}({\textbf{x}})$
is homogeneous in the bi-limit with associated triples
 $({{{\textbf{r}}_0},{d_0},{{\textbf{f}}_0}({\textbf{x}})})$
and
 $({{{\textbf{r}}_\infty },{d_\infty },{{\textbf{f}}_\infty }({\textbf{x}})})$
, and the systems
 ${\dot{\textbf{x}}} = {\textbf{f}}({\textbf{x}})$
,
 ${\dot{\textbf{x}}} = {{\textbf{f}}_0}({\textbf{x}})$
, and
 ${\dot{\textbf{x}}} = {{\textbf{f}}_\infty }({\textbf{x}})$
are globally asymptotically stable with the condition
 ${d_\infty } \gt 0 \gt {d_0}$
, then system (14) is globally fixed-time stable.
Lemma 2. [Reference Cruz-Zavala, Moreno and Fridman28] The following system
 \begin{align}\left\{ \begin{array}{l}{{\dot x}_1} = - {\mu _1}\left( {{\rm{si}}{{\rm{g}}^{1/2}}\left( {{x_1}} \right) + \gamma {\rm{si}}{{\rm{g}}^{3/2}}\left( {{x_1}} \right)} \right) + {x_2},\\[5pt] {{\dot x}_2} \in - {\mu _2}\left( {\dfrac{1}{2}{\rm{sgn}}\left( {{x_1}} \right) + 2\gamma {\rm{sig}}\left( {{x_1}} \right) + {3 \over 2}{\gamma ^2}{\rm{si}}{{\rm{g}}^2}\left( {{x_1}} \right)} \right) + \left[ { - b,b} \right],\end{array} \right.\end{align}
where
 ${\mu _1}$
,
 ${\mu _2}$
, and
 $\gamma $
are appropriate positive constants and
 $b \ge 0$
is globally fixed-time stable.
3. Control design and stability analysis
3.1. Flowchart of the whole control design procedure
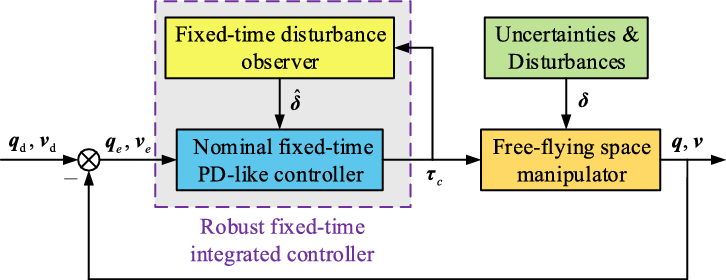
The main results of this work are provided in this section. First, a nominal fixed-time PD-like controller is designed by utilizing the bi-limit homogeneous method. The nominal fixed-time PD-like controller can ensure the position and velocity tracking errors regulate to zero in fixed time in the absence of lumped disturbance. Then, a robust fixed-time integrated controller is developed by integrating the nominal fixed-time PD-like controller with a fixed-time disturbance observer. The robust fixed-time integrated controller can ensure the position and velocity tracking errors regulate to zero in fixed time even subject to lumped disturbance. To make the readers have a clear understanding about the whole control design procedure, the flowchart of the proposed robust fixed-time integrated control approach is depicted in Fig. 2.
Diagram of the proposed robust fixed-time integrated control approach.

3.2. Nominal fixed-time PD-like control design without lumped disturbance
First, suppose the case that there exists no lumped disturbance acted on the space manipulator. A nominal fixed-time PD-like controller is designed by utilizing the bi-limit homogeneous method.
Theorem 1. Consider the space manipulator system (12) in the absence of lumped disturbance. If the nominal fixed-time PD-like controller is designed as
 \begin{align}{{\boldsymbol\tau }} = - {{\textbf{M}}^ * }({\textbf{q}})\left( {{k_1}{\rm{si}}{{\rm{g}}^{{\alpha _1}}}({{{\textbf{q}}_e}}) + {k_2}{\rm{si}}{{\rm{g}}^{{\alpha _2}}}({{{\textbf{v}}_e}}) + {h_1}{\rm{si}}{{\rm{g}}^{{\beta _1}}}({{{\textbf{q}}_e}}) + {h_2}{\rm{si}}{{\rm{g}}^{{\beta _2}}}({{{\textbf{v}}_e}})} \right) + {{\textbf{M}}^ * }({\textbf{q}}){{\ddot{\textbf{q}}}_{\rm{d}}} + {{\textbf{C}}^ * }({{\textbf{q}},{\dot{\textbf{q}}}}){\dot{\textbf{q}}},\end{align}
where
 $0 \lt {\alpha _1} \lt 1$
,
 ${\alpha _2} = 2{\alpha _1}/({{\alpha _1} + 1})$
,
 ${\beta _1} = 2{\alpha _1} + 1$
,
 ${\beta _2} = ({2{\alpha _1} + 1})/({{\alpha _1} + 1})$
, and
 ${k_1}$
,
 ${k_2}$
,
 ${h_1}$
, and
 ${h_2}$
are positive control parameters, then the whole closed-loop system is globally fixed-time stable and the position and velocity tracking errors
 ${{\textbf{q}}_e}$
and
 ${{\textbf{v}}_e}$
can regulate to zero in fixed time.
Proof. In the absence of lumped disturbance, substituting the nominal fixed-time PD-like controller (17) into (12), the whole closed-loop system can be obtained as
 \begin{align}\left\{ \begin{array}{l}{{{\dot{\textbf{q}}}}_e} = {{\textbf{v}}_e},\\{{{\dot{\textbf{v}}}}_e} = -{k_1}{\rm{si}}{{\rm{g}}^{{\alpha _1}}}({{{\textbf{q}}_e}}) - {k_2}{\rm{si}}{{\rm{g}}^{{\alpha _2}}}({{{\textbf{v}}_e}}) - {h_1}{\rm{si}}{{\rm{g}}^{{\beta _1}}}({{{\textbf{q}}_e}}) - {h_2}{\rm{si}}{{\rm{g}}^{{\beta _2}}}({{{\textbf{v}}_e}}).\end{array} \right.\end{align}
Define a vector
 ${\textbf{x}} = {\left[ {{\textbf{q}}_e^{\rm{T}},{\textbf{v}}_e^{\rm{T}}} \right]^{\rm{T}}} \in {\mathbb {R}^{2n}}$
, then system (18) can be represented as
 ${\dot{\textbf{x}}} = {\textbf{f}}({\textbf{x}})$
. The remaining proof of Theorem 1 contains two steps. In step 1, we will prove that
 ${\textbf{f}}({\textbf{x}})$
is homogeneous in the bi-limit with associated triples
 $({{{\textbf{r}}_0},{d_0},{{\textbf{f}}_0}({\textbf{x}})})$
and
 $({{{\textbf{r}}_\infty },{d_\infty },{{\textbf{f}}_\infty }({\textbf{x}})})$
. In Step 2, we will prove that the systems
 ${\dot{\textbf{x}}} = {\textbf{f}}({\textbf{x}})$
,
 ${\dot{\textbf{x}}} = {{\textbf{f}}_0}({\textbf{x}})$
, and
 ${\dot{\textbf{x}}} = {{\textbf{f}}_\infty }({\textbf{x}})$
are globally asymptotically stable.
Step 1: Homogeneity in the bi-limit of
 ${\textbf{f}}({\textbf{x}})$
.
Construct the following approximating vector field:
 \begin{align}{{\textbf{f}}_0}({\textbf{x}}) = {\left[ {{\textbf{v}}_e^{\rm{T}},{{\left( { - {k_1}{\rm{si}}{{\rm{g}}^{{\alpha _1}}}({{{\textbf{q}}_e}}) - {k_2}{\rm{si}}{{\rm{g}}^{{\alpha _2}}}({{{\textbf{v}}_e}})} \right)}^{\rm{T}}}} \right]^{\rm{T}}}.\end{align}
If we set
 ${{\textbf{r}}_0} = \left( {{r_{0,1}}, \ldots ,{r_{0,1}},{r_{0,2}}, \ldots ,{r_{0,2}}} \right) = \left( {2, \ldots ,2,{\alpha _1} + 1, \ldots ,{\alpha _1} + 1} \right)$
and
 ${d_0} = {\alpha _1} - 1 \lt 0$
, it can be verified that
 \begin{align}\left\{ \begin{array}{l}{r_{0,2}} = {d_0} + {r_{0,1}},\\{\alpha _1}{r_{0,1}} = {\alpha _2}{r_{0,2}} = {d_0} + {r_{0,2}}.\end{array} \right.\end{align}
By Definition 2, we have
 ${\textbf{f}}({\textbf{x}})$
is homogeneous in the 0-limit with associated triple
 $\left( {{{\textbf{r}}_0},{d_0},{{\textbf{f}}_0}({\textbf{x}})} \right)$
. Moreover, construct another approximating vector field:
 \begin{align}{{\textbf{f}}_\infty }({\textbf{x}}) = {\left[ {{\textbf{v}}_e^{\rm{T}},{{\left( { - {h_1}{\rm{si}}{{\rm{g}}^{{\beta _1}}}({{{\textbf{q}}_e}}) - {h_2}{\rm{si}}{{\rm{g}}^{{\beta _2}}}({{{\textbf{v}}_e}})} \right)}^{\rm{T}}}} \right]^{\rm{T}}}.\end{align}
If we set
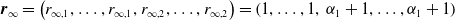 ${{\textbf{r}}_\infty } = \left( {{r_{\infty ,1}}, \ldots ,{r_{\infty ,1}},{r_{\infty ,2}}, \ldots ,{r_{\infty ,2}}} \right) = \left( {1, \ldots ,1,\,{\alpha _1} + 1, \ldots ,{\alpha _1} + 1} \right)$
and
 ${d_\infty } = {\alpha _1} \gt 0$
, it can be verified that
 \begin{align}\left\{ \begin{array}{l}{r_{\infty ,2}} = {d_\infty } + {r_{\infty ,1}},\\{\beta _1}{r_{\infty ,1}} = {\beta _2}{r_{\infty ,2}} = {d_\infty } + {r_{\infty ,2}}.\end{array} \right.\end{align}
By Definition 2, we have
 ${\textbf{f}}({\textbf{x}})$
is homogeneous in the ∞-limit with associated triple
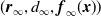 $({{{\textbf{r}}_\infty },{d_\infty },{{\textbf{f}}_\infty }({\textbf{x}})})$
. Then, by Definition 3,
 ${\textbf{f}}({\textbf{x}})$
is homogeneous in the bi-limit with associated triples
 $({{{\textbf{r}}_0},{d_0},{{\textbf{f}}_0}({\textbf{x}})})$
and
 $({{{\textbf{r}}_\infty },{d_\infty },{{\textbf{f}}_\infty }({\textbf{x}})})$
.
Step 2: Global asymptotic stability of the systems
 ${\dot{\textbf{x}}} = {\textbf{f}}({\textbf{x}})$
,
 ${\dot{\textbf{x}}} = {{\textbf{f}}_0}({\textbf{x}})$
, and
 ${\dot{\textbf{x}}} = {{\textbf{f}}_\infty }({\textbf{x}})$
.
For system (18), construct the following Lyapunov function:
 \begin{align}V = \frac{1}{{{\alpha _1} + 1}}\sum\limits_{i = 1}^3 {{k_1}{{\left| {{q_{ei}}} \right|}^{{\alpha _1} + 1}}} + \frac{1}{{{\beta _1} + 1}}\sum\limits_{i = 1}^3 {{h_1}{{\left| {{q_{ei}}} \right|}^{{\beta _1} + 1}}} + \frac{1}{2}\sum\limits_{i = 1}^3 {{{\left| {{v_{ei}}} \right|}^2}} .\end{align}
Differentiating
 $V$
with respect to time and substituting (18) into it, we have
 \begin{align}\begin{array}{l}\dot V = {k_1}{\textbf{v}}_e^{\rm{T}}{\rm{si}}{{\rm{g}}^{{\alpha _1}}}({{{\textbf{q}}_e}}) + {h_1}{\textbf{v}}_e^{\rm{T}}{\rm{si}}{{\rm{g}}^{{\beta _1}}}({{{\textbf{q}}_e}}) + {\textbf{v}}_e^{\rm{T}}{{{\dot{\textbf{v}}}}_e}\\[5pt] \;\;\;\; = - {k_2}{\textbf{v}}_e^{\rm{T}}{\rm{si}}{{\rm{g}}^{{\alpha _2}}}({{{\textbf{v}}_e}}) - {h_2}{\textbf{v}}_e^{\rm{T}}{\rm{si}}{{\rm{g}}^{{\beta _2}}}({{{\textbf{v}}_e}}).\end{array}\end{align}
From (24), we have
 $\dot V \le 0$
. Actually,
 $\dot V \equiv 0$
means
 ${{\textbf{v}}_e}\left( t \right) = {\textbf{0}_n}$
. By LaSalle’s invariance principle [Reference Slotine and Li36], it follows that
 ${{\textbf{q}}_e}\left( t \right) = {\textbf{0}_n}$
. Thus, the closed-loop system (18) is globally asymptotically stable about the equilibrium
 ${\textbf{x}} = {\textbf{0}_{2n}}$
. Furthermore, for system
 ${\dot{\textbf{x}}} = {{\textbf{f}}_0}({\textbf{x}})$
, construct the Lyapunov function as
 \begin{align}{V_0} = \frac{1}{{{\alpha _1} + 1}}\sum\limits_{i = 1}^3 {{k_1}{{\left| {{q_{ei}}} \right|}^{{\alpha _1} + 1}}} + \frac{1}{2}\sum\limits_{i = 1}^3 {{{\left| {{v_{ei}}} \right|}^2}} .\end{align}
For system
 ${\dot{\textbf{x}}} = {{\textbf{f}}_\infty }({\textbf{x}})$
, construct the Lyapunov function as
 \begin{align}{V_\infty } = \frac{1}{{{\beta _1} + 1}}\sum\limits_{i = 1}^3 {{h_1}{{\left| {{q_{ei}}} \right|}^{{\beta _1} + 1}}} + \frac{1}{2}\sum\limits_{i = 1}^3 {{{\left| {{v_{ei}}} \right|}^2}} .\end{align}
Likewise, it can be obtained that
 ${\dot{\textbf{x}}} = {{\textbf{f}}_0}({\textbf{x}})$
and
 ${\dot{\textbf{x}}} = {{\textbf{f}}_\infty }({\textbf{x}})$
are also globally asymptotically stable.
Combining the results of Steps 1 and 2,
 ${\textbf{f}}({\textbf{x}})$
is homogeneous in the bi-limit with associated triples
 $\left( {{{\textbf{r}}_0},{d_0},{{\textbf{f}}_0}({\textbf{x}})} \right)$
and
 $\left( {{{\textbf{r}}_\infty },{d_\infty },{{\textbf{f}}_\infty }({\textbf{x}})} \right)$
and the systems
 ${\dot{\textbf{x}}} = {\textbf{f}}({\textbf{x}})$
,
 ${\dot{\textbf{x}}} = {{\textbf{f}}_0}({\textbf{x}})$
, and
 ${\dot{\textbf{x}}} = {{\textbf{f}}_\infty }({\textbf{x}})$
are globally asymptotically stable with the condition
 ${d_\infty } \gt 0 \gt {d_0}$
. Then, by Lemma 1, system (18) is globally fixed-time stable and the position and velocity tracking errors
 ${{\textbf{q}}_e}$
and
 ${{\textbf{v}}_e}$
can regulate to zero in fixed time in the absence of lumped disturbance. There exists a time constant
 ${T_1}$
such that
 ${{\textbf{q}}_e}\left( t \right) = {\textbf{0}_n}$
and
 ${{\textbf{v}}_e}\left( t \right) = {\textbf{0}_n}$
,
 $\forall t \gt {T_1}$
. The proof is thus finished.
3.3. Robust fixed-time integrated control design with lumped disturbance
Then, suppose the case that there exists lumped disturbance acted on the space manipulator. A robust fixed-time integrated controller is developed by integrating the nominal fixed-time PD-like controller with a fixed-time disturbance observer.
Theorem 2. Consider the space manipulator system (12) in the presence of lumped disturbance under Assumption 1. If the fixed-time disturbance observer is designed as
 \begin{align}\left\{ \begin{array}{l} {{{\dot{\hat{\textbf{v}}}}}_e} = - {{\textbf{M}}^{ * - 1}}({\textbf{q}}){{\textbf{C}}^ * }({{\textbf{q}},{\dot{\textbf{q}}}}){\dot{\textbf{q}}} + {{\textbf{M}}^{ * - 1}}({\textbf{q}}){{\boldsymbol\tau }} + {\hat{\boldsymbol\delta }} - {{{\ddot{\textbf{q}}}}_{\rm{d}}} - {\mu _1}\left( {{\rm{si}}{{\rm{g}}^{1/2}}\left( {{{{\hat{\textbf{v}}}}_e} - {{\textbf{v}}_e}} \right) + \gamma {\rm{si}}{{\rm{g}}^{3/2}}\left( {{{{\hat{\textbf{v}}}}_e} - {{\textbf{v}}_e}} \right)} \right), \\[5pt] \dot{\hat{\boldsymbol\delta }} = - {\mu _2}\left( {{1 \over 2}{\rm{sgn}}\left( {{{{\hat{\textbf{v}}}}_e} - {{\textbf{v}}_e}} \right) + 2\gamma {\rm{sig}}\left( {{{{\hat{\textbf{v}}}}_e} - {{\textbf{v}}_e}} \right) + {3 \over 2}{\gamma ^2}{\rm{si}}{{\rm{g}}^2}\left( {{{{\hat{\textbf{v}}}}_e} - {{\textbf{v}}_e}} \right)} \right), \hfill \end{array} \right.\end{align}
where
 ${\mu _1}$
,
 ${\mu _2}$
, and
 $\gamma $
are positive control parameters, and
 ${{\hat{\textbf{v}}}_e}$
and
 ${\hat{\boldsymbol\delta }}$
are the estimations of
 ${{\textbf{v}}_e}$
and
 ${{\boldsymbol\delta }}$
, then the observer error system is globally fixed-time stable and the lumped disturbance
 ${{\boldsymbol\delta }}$
can be exactly estimated in fixed time.
Proof. Define the estimation errors
 ${\tilde{\textbf{v}}_e} = {{\hat{\textbf{v}}}_e} - {{\textbf{v}}_e}$
and
 ${\tilde{\boldsymbol\delta }} = {\hat{\boldsymbol\delta }} - {{\boldsymbol\delta }}$
. Substituting the fixed-time disturbance observer (27) into (12), the observer error system can be obtained as
 \begin{align}\left\{ \begin{array}{l} {{\dot{\tilde{\textbf{v}}}}_e} = - {\mu _1}\left( {{\rm{si}}{{\rm{g}}^{1/2}}({{{\tilde{\textbf{v}}}_e}}) + \gamma {\rm{si}}{{\rm{g}}^{{{3}}/{{2}}}}\left( {{{\tilde{\textbf{v}}}_{\textbf{e}}}} \right)} \right) + \tilde{\boldsymbol\delta} , \\[5pt] \dot{\tilde{\boldsymbol\delta}} = - {\mu _2}\left( {{1 \over 2}{\rm{sgn}}({{{\tilde{\textbf{v}}}_e}}) + 2\gamma {\rm{sig}}({{{\tilde{\textbf{v}}}_e}}) + {3 \over 2}{\gamma ^2}{\rm{si}}{{\rm{g}}^2}({{{\tilde{\textbf{v}}}_e}})} \right) - {\dot{\boldsymbol\delta}} . \end{array} \right.\end{align}
Together with Assumption 1, the observer error system can be rewritten as
 \begin{align}\left\{ \begin{array}{l} {{\dot{\tilde{v}}}_{ei}} = - {\mu _1}\left( {{\rm{si}}{{\rm{g}}^{1/2}}\left( {{{\tilde v}_{ei}}} \right) + \gamma {\rm{si}}{{\rm{g}}^{3/2}}\left( {{{\tilde v}_{ei}}} \right)} \right) + {{\tilde \delta }_i},\;\;\;\;i = 1,2, \ldots ,n, \\[5pt] {{\dot{\tilde{\delta}}}_i} \in - {\mu _2}\left( {{1 \over 2}{\rm{sgn}}\left( {{{\tilde v}_{ei}}} \right) + 2\gamma {\rm{sig}}\left( {{{\tilde v}_{ei}}} \right) + {3 \over 2}{\gamma ^2}{\rm{si}}{{\rm{g}}^2}\left( {{{\tilde v}_{ei}}} \right)} \right) + \left[ { - b,b} \right],\;\;\;\;i = 1,2, \ldots ,n. \end{array} \right.\end{align}
Then, by Lemma 2, the observer error system (28) is globally fixed-time stable and the lumped disturbance
 ${{\boldsymbol\delta }}$
can be exactly estimated in fixed time. There exists a time constant
 ${T_2}$
such that
 ${\tilde{\textbf{v}}_e}\left( t \right) = {\textbf{0}_n}$
and
 ${\tilde{\boldsymbol\delta }}(t) = {\textbf{0}_n}$
,
 $\forall t \gt {T_2}$
. The proof is thus finished.
Now, we are ready to put forward the main results of this research.
Theorem 3. Consider the space manipulator system (12) in the presence of lumped disturbance under Assumption 1. If the robust fixed-time integrated controller is designed as
 \begin{align}{{{\boldsymbol\tau }}_c} = {{\boldsymbol\tau }} + {{{\boldsymbol\tau }}_r},\end{align}
where
 ${{\boldsymbol\tau }}$
is designed as (17), and
 ${{{\boldsymbol\tau }}_r} = - {{\textbf{M}}^ * }({\textbf{q}}){\hat{\boldsymbol\delta }}$
is the feedforward compensation term, in which
 ${\hat{\boldsymbol\delta }}$
is generated by the fixed-time disturbance observer (27), then the whole closed-loop system is globally fixed-time stable and the position and velocity tracking errors
 ${{\textbf{q}}_e}$
and
 ${{\textbf{v}}_e}$
can regulate to zero in fixed time.
Proof. In the presence of lumped disturbance, substituting the robust fixed-time integrated controller (30) into (12), the whole closed-loop system can be obtained as
 \begin{align}\left\{ \begin{array}{l}{{{\dot{\textbf{q}}}}_e} = {{\textbf{v}}_e},\\{{{\dot{\textbf{v}}}}_e} = - {k_1}{\rm{si}}{{\rm{g}}^{{\alpha _1}}}({{{\textbf{q}}_e}}) - {k_2}{\rm{si}}{{\rm{g}}^{{\alpha _2}}}({{{\textbf{v}}_e}}) - {h_1}{\rm{si}}{{\rm{g}}^{{\beta _1}}}({{{\textbf{q}}_e}}) - {h_2}{\rm{si}}{{\rm{g}}^{{\beta _2}}}({{{\textbf{v}}_e}}) + {\tilde{\boldsymbol\delta }}.\end{array} \right.\end{align}
The remaining proof of Theorem 3 contains two steps. In Step 1, we will prove that the closed-loop system (31) is globally fixed-time stable when
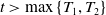 $t \gt \max \left\{ {{T_1},{T_2}} \right\}$
. In Step 2, we will prove that the system states will never diverge to infinity during the time interval
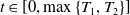 $t \in \left[ {0,\max \left\{ {{T_1},{T_2}} \right\}} \right]$
.
Step 1: Global fixed-time stability of the closed-loop system (31) when
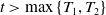 $t \gt \max \left\{ {{T_1},{T_2}} \right\}$
.
By Theorem 2, we have
 ${\tilde{\boldsymbol\delta }}\left( t \right) = {\textbf{0}_n}$
,
 $\forall t \ge {T_2}$
. Thus, when
 $t \gt {T_2}$
, system (31) can reduce to system (18). Then, by Theorem 1, it follows that system (31) is globally fixed-time stable and the position and velocity tracking errors
 ${{\textbf{q}}_e}$
and
 ${{\textbf{v}}_e}$
can regulate to zero in fixed time in the presence of lumped disturbance when
 $t \gt \max \left\{ {{T_1},{T_2}} \right\}$
.
Step 2: Boundedness of the system states during the time interval
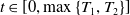 $t \in \left[ {0,\max \left\{ {{T_1},{T_2}} \right\}} \right]$
.
Construct the following Lyapunov function:
 \begin{align}L = \frac{1}{2}\left( {{\textbf{q}}_e^{\rm{T}}{{\textbf{q}}_e} + {\textbf{v}}_e^{\rm{T}}{{\textbf{v}}_e} + {\hat{\textbf{v}}}_e^{\rm{T}}{{{\hat{\textbf{v}}}}_e} + {{{\hat{\boldsymbol\delta }}}^{\rm{T}}}{\hat{\boldsymbol\delta }}} \right).\end{align}
Differentiating
 $L$
with respect to time and substituting (27) and (31) into it, we have
 \begin{align} \dot L &= {\textbf{q}}_e^{\rm{T}}{{{\dot{\textbf{q}}}}_e} + {\textbf{v}}_e^{\rm{T}}{{{\dot{\textbf{v}}}}_e} + {\hat{\textbf{v}}}_e^{\rm{T}}{{{\dot{\hat{\textbf{v}}}}}_e} + {{{\hat{\boldsymbol\delta }}}^{\rm{T}}}\dot{\hat{\boldsymbol\delta }} \nonumber \\ & = {\textbf{q}}_e^{\rm{T}}{{\textbf{v}}_e} + {\textbf{v}}_e^{\rm{T}}\left( { - {k_1}{\rm{si}}{{\rm{g}}^{{\alpha _1}}}({{{\textbf{q}}_e}}) - {k_2}{\rm{si}}{{\rm{g}}^{{\alpha _2}}}({{{\textbf{v}}_e}}) - {h_1}{\rm{si}}{{\rm{g}}^{{\beta _1}}}({{{\textbf{q}}_e}}) - {h_2}{\rm{si}}{{\rm{g}}^{{\beta _2}}}({{{\textbf{v}}_e}}) + {\tilde{\boldsymbol\delta }}} \right) \nonumber \\ & \quad + {\hat{\textbf{v}}}_e^{\rm{T}}\left( { - {k_1}{\rm{si}}{{\rm{g}}^{{\alpha _1}}}({{{\textbf{q}}_e}}) - {k_2}{\rm{si}}{{\rm{g}}^{{\alpha _2}}}({{{\textbf{v}}_e}}) - {h_1}{\rm{si}}{{\rm{g}}^{{\beta _1}}}({{{\textbf{q}}_e}}) - {h_2}{\rm{si}}{{\rm{g}}^{{\beta _2}}}({{{\textbf{v}}_e}}) - {\mu _1}\left( {{\rm{si}}{{\rm{g}}^{1/2}}({{{\tilde{\textbf{v}}}_e}}) + \gamma {\rm{si}}{{\rm{g}}^{3/2}}({{{\tilde{\textbf{v}}}_e}})} \right)} \right) \nonumber \\ & \quad + {{{\hat{\boldsymbol\delta }}}^{\rm{T}}}\left( { - {\mu _2}\left( {{1 \over 2}{\rm{sgn}}({{{\tilde{\textbf{v}}}_e}}) + 2\gamma {\rm{sig}}({{{\tilde{\textbf{v}}}_e}}) + {3 \over 2}{\gamma ^2}{\rm{si}}{{\rm{g}}^2}({{{\tilde{\textbf{v}}}_e}})} \right)} \right). \end{align}
By Theorem 2, we have
 ${\tilde{\boldsymbol\delta }}\left( t \right) = {\textbf{0}_n}$
,
 $\forall t \ge {T_2}$
. It follows that
 ${\tilde{\boldsymbol\delta }}$
is bounded. There exists an unknown positive constant
 $\bar \delta $
such that
 $\left| {{{\tilde \delta }_i}} \right| \le \bar \delta $
. Moreover, consider the following inequalities hold:
 \begin{align} {\hat{\textbf{v}}}_e^{\rm{T}}\left( { - {\mu _1}\left( {{\rm{si}}{{\rm{g}}^{1/2}}({{{\tilde{\textbf{v}}}_e}}) + \gamma {\rm{si}}{{\rm{g}}^{3/2}}({{{\tilde{\textbf{v}}}_e}})} \right)} \right) & \le \sum\limits_{i = 1}^3 {{\mu _1}\left| {{{\hat v}_{ei}}} \right|\left( {{{\left| {{{\hat v}_{ei}} - {v_{ei}}} \right|}^{1/2}} + \gamma {{\left| {{{\hat v}_{ei}} - {v_{ei}}} \right|}^{3/2}}} \right)} \nonumber \\ & \le \sum\limits_{i = 1}^3 {{\mu _1}\left| {{{\hat v}_{ei}}} \right|\left( {{{\left| {{{\hat v}_{ei}}} \right|}^{1/2}} + {{\left| {{v_{ei}}} \right|}^{1/2}} + \gamma \left( {{{\left| {{{\hat v}_{ei}}} \right|}^{3/2}} + {{\left| {{v_{ei}}} \right|}^{3/2}}} \right)} \right)} , \end{align}
 \begin{align} & {{{\hat{\boldsymbol\delta }}}^{\rm{T}}}\left( { - {\mu _2}\left( {{1 \over 2}{\rm{sgn}}({{{\tilde{\textbf{v}}}_e}}) + 2\gamma {\rm{sig}}({{{\tilde{\textbf{v}}}_e}}) + {3 \over 2}{\gamma ^2}{\rm{si}}{{\rm{g}}^2}({{{\tilde{\textbf{v}}}_e}})} \right)} \right) \nonumber \\ & \quad \le \sum\limits_{i = 1}^3 {{\mu _2}\left| {{{\hat \delta }_i}} \right|\left( {{1 \over 2} + 2\gamma {{\left| {{{\hat v}_{ei}} - {v_{ei}}} \right|}^{1/2}} + {3 \over 2}{\gamma ^2}{{\left| {{{\hat v}_{ei}} - {v_{ei}}} \right|}^2}} \right)}\nonumber \\ & \quad \le \sum\limits_{i = 1}^3 {{\mu _2}\left| {{{\hat \delta }_i}} \right|\left( {{1 \over 2} + 2\gamma \left( {{{\left| {{{\hat v}_{ei}}} \right|}^{1/2}} + {{\left| {{v_{ei}}} \right|}^{1/2}}} \right) + {3 \over 2}{\gamma ^2}\left( {{{\left| {{{\hat v}_{ei}}} \right|}^2} + {{\left| {{v_{ei}}} \right|}^2}} \right)} \right)} . \end{align}
Define a new variable
 $\vartheta \buildrel \Delta \over = \sqrt {{\textbf{q}}_e^{\rm{T}}{{\textbf{q}}_e} + {\textbf{v}}_e^{\rm{T}}{{\textbf{v}}_e} + {\hat{\textbf{v}}}_e{}^{\!\!\!\rm{T}}{{{\hat{\textbf{v}}}}_e} + {{{\hat{\boldsymbol\delta }}{}^{\rm{T}}}}{\hat{\boldsymbol\delta }}} $
. It follows that
 $\left| {{q_{ei}}} \right| \le \vartheta $
,
 $\left| {{v_{ei}}} \right| \le \vartheta $
,
 $\left| {{{\hat v}_{ei}}} \right| \le \vartheta $
, and
 $\left| {{{\hat \delta }_i}} \right| \le \vartheta $
. The following analysis can be divided into two cases. On the one hand, if
 $\vartheta \gt 1$
, substituting (34) and (35) into (33) yields
 $$\matrix{
{} \hfill & {\dot L \le \sum\limits_{i = 1}^3 {{\vartheta ^2}} + \sum\limits_{i = 1}^3 {\vartheta \left( {{k_1}{\vartheta ^{{\alpha _1}}} + {k_2}{\vartheta ^{{\alpha _2}}} + {h_1}{\vartheta ^{{\beta _1}}} + {h_2}{\vartheta ^{{\beta _2}}}} \right)} + \sum\limits_{i = 1}^3 {\bar \delta \vartheta } {\rm{ }}} \hfill \cr
{} \hfill & { + \sum\limits_{i = 1}^3 {\vartheta \left( {{k_1}{\vartheta ^{{\alpha _1}}} + {k_2}{\vartheta ^{{\alpha _2}}} + {h_1}{\vartheta ^{{\beta _1}}} + {h_2}{\vartheta ^{{\beta _2}}}} \right)} + \sum\limits_{i = 1}^3 {{\mu _1}\vartheta \left( {{\vartheta ^{1/2}} + {\vartheta ^{1/2}} + \gamma \left( {{\vartheta ^{3/2}} + {\vartheta ^{3/2}}} \right)} \right)} } \hfill \cr
\qquad \hfill & { + \sum\limits_{i = 1}^3 {{\mu _2}\vartheta \left( {{1 \over 2} + 2\gamma \left( {{\vartheta ^{1/2}} + {\vartheta ^{1/2}}} \right) + {3 \over 2}{\gamma ^2}\left( {{\vartheta ^2} + {\vartheta ^2}} \right)} \right)} } \hfill \cr
{} \hfill & { \le {\eta _1}{\vartheta ^2} + {\eta _2}{\vartheta ^3}} \hfill \cr
{} \hfill & { = 2{\eta _1}L + 2{\eta _2}{L^{3/2}},} \hfill \cr
} $$
where
 ${\eta _1} = 3 + 6{k_1} + 6{k_2} + 3\bar \delta + 6{\mu _1} + \frac{3}{2}{\mu _2} + 12{\mu _2}\gamma $
and
 ${\eta _2} = 6{h_1} + 6{h_2} + 6{\mu _1}\gamma + 9{\mu _2}{\gamma ^2}$
. On the other hand, if
 $\vartheta \le 1$
, we have
 $\dot L \le {\eta _1} + {\eta _2}$
. From the above analysis, we can obtain the fact that
 \begin{align}\dot L \le 2{\eta _1}L + 2{\eta _2}{L^{3/2}} + {\eta _1} + {\eta _2}.\end{align}
From (37), we have
 $L$
is bounded during the whole trajectory tracking process. Together with the definition of
 $L$
, it can be obtained that the system states
 ${{\textbf{q}}_e}$
,
 ${{\textbf{v}}_e}$
,
 ${{\hat{\textbf{v}}}_e}$
, and
 ${\hat{\boldsymbol\delta }}$
are all bounded during the time interval
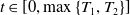 $t \in \left[ {0,\max \left\{ {{T_1},{T_2}} \right\}} \right]$
.
Combining the results of Steps 1 and 2, the closed-loop system (31) is globally fixed-time stable when
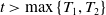 $t \gt \max \left\{ {{T_1},{T_2}} \right\}$
and the system states will never diverge to infinity during the time interval
 $t \in \left[ {0,\max \left\{ {{T_1},{T_2}} \right\}} \right]$
. Then, it follows that the closed-loop system (31) is globally fixed-time stable and the position and velocity tracking errors
 ${{\textbf{q}}_e}$
and
 ${{\textbf{v}}_e}$
can regulate to zero in fixed time in the presence of lumped disturbance. There exists a time constant
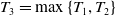 ${T_3} = \max \left\{ {{T_1},{T_2}} \right\}$
such that
 ${{\textbf{q}}_e}\left( t \right) = {\textbf{0}_n}$
and
 ${{\textbf{v}}_e}\left( t \right) = {\textbf{0}_n}$
,
 $\forall t \gt {T_3}$
. The proof is thus finished.
3.4. Control parameter selection
To make the proposed robust fixed-time integrated controller more friendly to the users, a universal control parameter selection strategy is introduced. The strategy can be mainly divided into three steps. In Step 1, we will determine the control parameters
 ${\alpha _1}$
,
 ${\alpha _2}$
,
 ${\beta _1}$
, and
 ${\beta _2}$
. The relationships
 $0 \lt {\alpha _1} \lt 1$
,
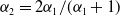 ${\alpha _2} = 2{\alpha _1}/({{\alpha _1} + 1})$
,
 ${\beta _1} = 2{\alpha _1} + 1$
, and
 ${\beta _2} = ({2{\alpha _1} + 1})/({{\alpha _1} + 1})$
must be obeyed. In Sep 2, we will determine the control parameters
 ${k_1}$
,
 ${k_2}$
,
 ${h_1}$
, and
 ${h_2}$
. Large
 ${k_1}$
,
 ${k_2}$
,
 ${h_1}$
, and
 ${h_2}$
can result in the relatively high control accuracy and fast convergence rate. However, they may lead to relatively big control torques, which may be unrealistic in practice. Moreover, we usually select
 ${k_1} \ge {h_1}$
and
 ${k_2} \ge {h_2}$
. In Step 3, we will determine the control parameters
 ${\mu _1}$
and
 ${\mu _2}$
. Large
 ${\mu _1}$
and
 ${\mu _2}$
can result in the relatively fast convergence rate. However, they may also lead to the relatively poor transient response performance in the meantime. Hence, the control parameters of the proposed controller should be carefully selected by trial and error to achieve the satisfactory tracking performance with appropriate control torques.
4. Simulations and comparisons
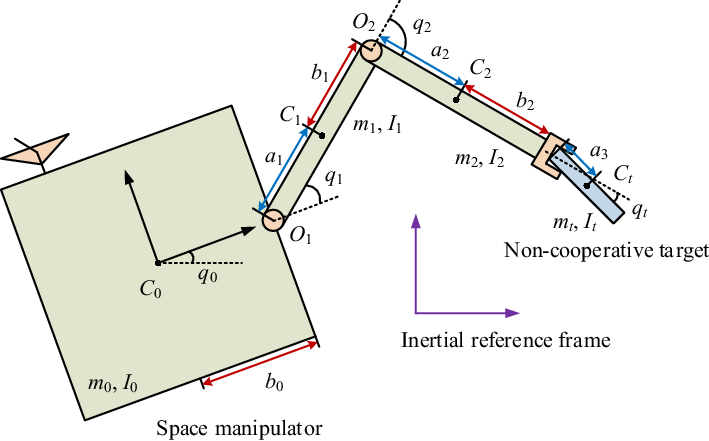
In this section, numerical simulations are made on a planar free-flying two-link space manipulator grasping a non-cooperative target as shown in Fig. 3 to validate the proposed robust fixed-time integrated control approach. The detailed dynamic model of the two-link space manipulator can be found in [Reference Yao22,Reference Yao23].
Structure of a planar free-flying two-link space manipulator.

The nominal parameters of the space manipulator are chosen as
 $m_0^ * = 60\;{\rm{kg}}$
,
 $m_1^ * = 6\;{\rm{kg}}$
,
 $m_2^ * = 5\;{\rm{kg}}$
,
 $m_t^ * = 10\;{\rm{kg}}$
,
 $I_0^ * = 22.5\;{\rm{kg}} \cdot {{\rm{m}}^2}$
,
 $I_1^ * = 1.125\;{\rm{kg}} \cdot {{\rm{m}}^2}$
,
 $I_2^ * = 0.9375\;{\rm{kg}} \cdot {{\rm{m}}^2}$
,
 $I_t^ * = 2\;{\rm{kg}} \cdot {{\rm{m}}^2}$
,
 $b_0^ * = 0.75\;{\rm{m}}$
,
 $a_1^ * = 0.75\;{\rm{m}}$
,
 $b_1^ * = 0.75\;{\rm{m}}$
,
 $a_2^ * = 0.75\;{\rm{m}}$
,
 $b_2^ * = 0.75\;{\rm{m}}$
,
 $a_3^ * = 0.5\;{\rm{m}}$
, and
 $q_t^ * = \pi /6\,{\rm{rad}}$
, respectively. However, the space manipulator is perturbed by model uncertainties and external disturbances. The actual parameters of the space manipulator are set as
 ${m_0} = 64\;{\rm{kg}}$
,
 ${m_1} = 7.2\;{\rm{kg}}$
,
 ${m_2} = 5.6\;{\rm{kg}}$
,
 ${m_t} = 16\;{\rm{kg}}$
,
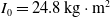 ${I_0} = 24.8\;{\rm{kg}} \cdot {{\rm{m}}^2}$
,
 ${I_1} = 1.44\;{\rm{kg}} \cdot {{\rm{m}}^2}$
,
 ${I_2} = 1.2\,{\rm{kg}} \cdot {{\rm{m}}^2}$
,
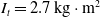 ${I_t} = 2.7\;{\rm{kg}} \cdot {{\rm{m}}^2}$
,
 ${b_0} = 0.75\;{\rm{m}}$
,
 ${a_1} = 0.75\;{\rm{m}}$
,
 ${b_1} = 0.75\;{\rm{m}}$
,
 ${a_2} = 0.75\;{\rm{m}}$
,
 ${b_2} = 0.75\;{\rm{m}}$
,
 ${a_3} = 0.62\;{\rm{m}}$
, and
 ${q_t} = \pi /6\,{\rm{rad}}$
, respectively. The external disturbances are set as
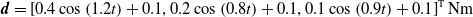 ${\textbf{d}} = {\left[ {0.4\cos \left( {1.2t} \right) + 0.1,0.2\cos \left( {0.8t} \right) + 0.1,0.1\cos \left( {0.9t} \right) + 0.1} \right]^{\rm{T}}}\;{\rm{Nm}}$
. Moreover, the desired position of the space manipulator is chosen as
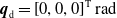 ${{\textbf{q}}_{\rm{d}}} = {\left[ {0,0,0} \right]^{\rm{T}}}\;{\rm{rad}}$
.
The following simulations can be divided into two parts. First, the proposed controller is compared with another two controllers to show the excellent tracking performance of the proposed controller. Then, four cases with different initial states of the space manipulator are conduced to test the fixed-time convergence capability of the proposed controller.
4.1. Performance comparisons
First, the proposed controller is compared with another two controllers to show the excellent tracking performance of the proposed controller. The initial position and velocity of the space manipulator are chosen as
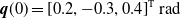 ${\textbf{q}}(0) = {\left[ {0.2, - 0.3,0.4} \right]^{\rm{T}}}\;{\rm{rad}}$
and
 ${\textbf{v}}(0) = {\left[ {0.04,0.02, - 0.03} \right]^{\rm{T}}}\;{\rm{rad/s}}$
, respectively. Besides the proposed robust fixed-time integrated controller (30), the nominal fixed-time PD-like controller (17) and the conventional sliding mode controller are also employed for performance comparisons. For the conventional sliding mode control design, the linear sliding surface is introduced as
 \begin{align}{\textbf{s}} = {{\textbf{v}}_e} + \mu {{\textbf{q}}_e},\end{align}
where
 $\mu $
is a positive constant. Then, the conventional sliding mode controller is designed as
 \begin{align}{{\boldsymbol\tau }} = - {{\textbf{M}}^ * }({\textbf{q}})\left( {k{\textbf{s}} + \eta {\mathop{\rm sgn}} \left( {\textbf{s}} \right)} \right) + {{\textbf{M}}^ * }({\textbf{q}}){{\ddot{\textbf{q}}}_{\rm{d}}} + {{\textbf{C}}^ * }({{\textbf{q}},{\dot{\textbf{q}}}}){\dot{\textbf{q}}},\end{align}
where
 $k$
and
 $\eta $
are positive constants. Moreover, the saturation function
 ${\rm{sat}}(\cdot)$
is utilized to replace the signum function
 ${\rm{sgn}}(\cdot)$
in the control design to reduce the chattering phenomenon. The elements of
 ${\rm{sat}}\left( {\textbf{s}} \right)$
are defined as
 \begin{align}{\rm{sat}}\left( {{s_i}} \right) = \left\{ \begin{matrix} {{\mathop{\rm sgn}} \left( {{s_i}} \right),\;\;\left| {{s_i}} \right| \ge \varepsilon ,} \\ {{s_i}/\varepsilon ,\;\;\left| {{s_i}} \right| \lt \varepsilon ,} \end{matrix} \right.\;i = 1,2,3,\end{align}
where
 $\varepsilon $
is a small positive constant.
In the simulations, the control parameters of the proposed robust fixed-time integrated controller (30) are selected as
 ${k_1} = 0.4$
,
 ${k_2} = 0.{\rm{8}}$
,
 ${h_1} = 0.1$
,
 ${h_2} = 0.{\rm{2}}$
,
 ${\alpha _1} = 1/3$
,
 ${\alpha _2} = 1/2$
,
 ${\beta _1} = 5/3$
,
 ${\beta _2} = 5/4$
,
 ${\mu _1} = 18$
,
 ${\mu _2} = 27$
, and
 $\gamma = 1$
. The initial conditions of the fixed-time disturbance observer are set as
 ${{\hat{\textbf{v}}}_e} = {{\textbf{v}}_e}(0)$
and
 ${\hat{\boldsymbol\delta }} = {\left[ {0,0,0} \right]^{\rm{T}}}$
. Moreover, the control parameters of the compared nominal fixed-time PD-like controller (17) are selected as
 ${k_1} = 0.4$
,
 ${k_2} = 0.{\rm{8}}$
,
 ${h_1} = 0.1$
,
 ${h_2} = 0.{\rm{2}}$
,
 ${\alpha _1} = 1/3$
,
 ${\alpha _2} = 1/2$
,
 ${\beta _1} = 5/3$
, and
 ${\beta _2} = 5/4$
. The control parameters of the compared conventional sliding mode controller (39) are selected as
 $\mu = 2$
,
 $k = 1$
,
 $\eta = 0.1$
, and
 $\varepsilon = 0.01$
.
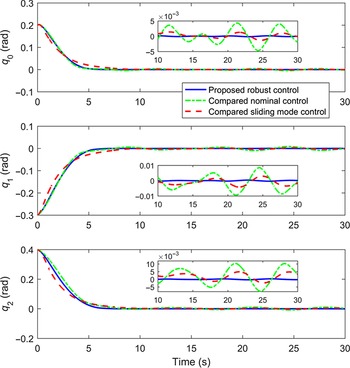
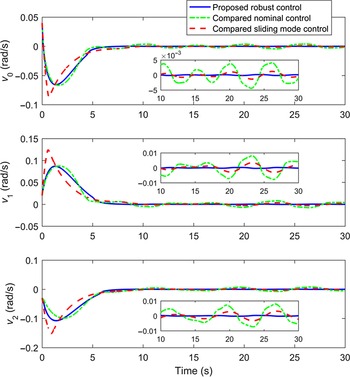
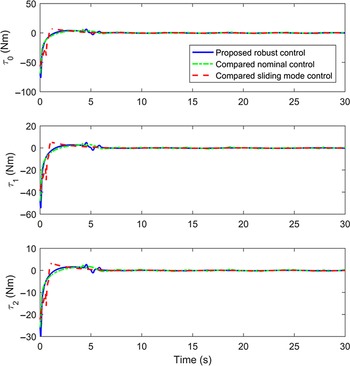
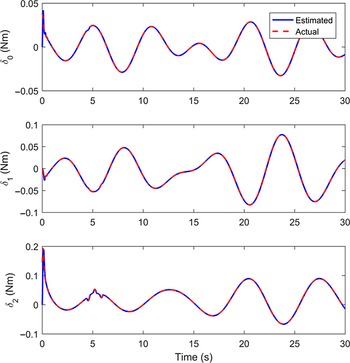
The simulation results for performance comparisons are presented in Figs. 4-7. Figures 4 and 5 show the time histories of the position and velocity tracking, respectively. It is clearly seen that the actual position and velocity under the proposed robust fixed-time integrated controller can regulate to the desired signals rapidly and accurately despite the space manipulator suffers from model uncertainties and external disturbances. However, the compared nominal fixed-time PD-like controller and conventional sliding mode controller can only achieve the relatively poor tracking performance due to the existence of lumped disturbance. The steady-state position and velocity tracking errors under the compared controllers are much larger than those under the proposed controller. Figure 6 shows the time history of the control torques. The control torques under these controllers are within the similar range during the whole trajectory tracking process and thus the comparisons are fair. The actual lumped disturbance and its estimation under the proposed controller are depicted in Fig. 7. The perfect observation can be obtained through the fixed-time disturbance observer. The estimation of the lumped disturbance can exactly and smoothly regulate to the actual one within a very short time. The fixed-time disturbance observer can be regarded as an indispensable component of the proposed robust fixed-time integrated controller. Benefiting from the disturbance observer-based feedforward compensation, the proposed controller can achieve the satisfactory tracking performance and excellent disturbance attenuation simultaneously.
Time history of the position tracking.

Time history of the velocity tracking.

Time history of the control torques.

Actual lumped disturbance and its estimation.

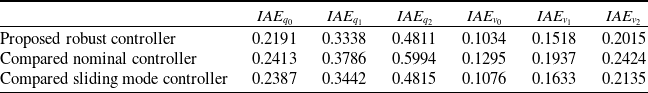
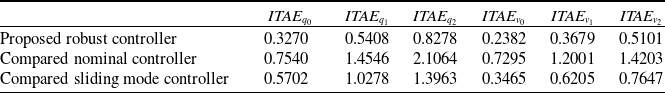
Furthermore, some critical indexes for the proposed controller and compared controllers are listed in Tables II and III to quantitatively compare the tracking performance between these controllers. Therein, the integrated absolute errors (IAEs) are defined as
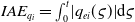 $IA{E_{{q_i}}} = \int_0^t\!{\left|{{q_{ei}}(\varsigma)}\right|\!{\rm{d}}\varsigma}$
and
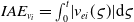 $IA{E_{{v_i}}} = \int_0^t\!{\left|{{v_{ei}}(\varsigma)}\right|\!{\rm{d}}\varsigma}$
, and the integrated time absolute errors (ITAEs) are defined as
 $ITA{E_{{q_i}}} = \int_0^t{\varsigma\!\left|{{q_{ei}}(\varsigma)}\right|\!{\rm{d}}\varsigma } $
and
 $ITA{E_{{v_i}}} = \int_0^t{\varsigma\!\left|{{v_{ei}}(\varsigma)}\right|\!{\rm{d}}\varsigma } $
 $(i = 0,1,2)$
with a total tracking time
 $t = 30\;{\rm{s}}$
. Comparing these indexes in Tables II and III, the proposed robust fixed-time integrated controller exhibits the smaller IAEs and ITAEs than the compared nominal fixed-time PD-like controller and conventional sliding mode controller. Actually, this means that the proposed controller can achieve the higher steady-state and transient response performance than the compared controllers.
IAEs of the different controllers.

ITAEs of the different controllers.

4.2. Fixed-time convergence tests
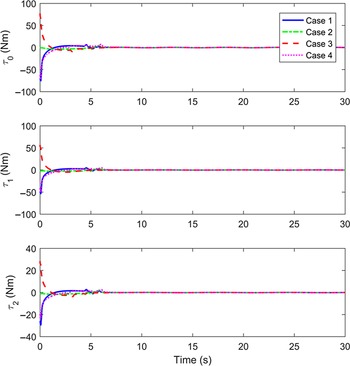
Then, four cases with different initial states of the space manipulator are conduced to test the fixed-time convergence capability of the proposed controller. The desired trajectory, model uncertainties, and external disturbances are chosen the same as those in Section 4.1. Moreover, the control parameters of the proposed controller are also selected the same as those in Section 4.1. The following four cases with different initial position and velocity of the space manipulator are considered for simulations.
-
• Case 1:
 ${\textbf{q}}(0) = {\left[ {0.2, - 0.3,0.4} \right]^{\rm{T}}}\;{\rm{rad}}$
and
${\textbf{v}}(0) = {\left[ {0.04,0.02, - 0.03} \right]^{\rm{T}}}\;{\rm{rad/s}}$
.
-
• Case 2:
${\textbf{q}}(0) = {\left[ { - 0.3,0.4, - 0.2} \right]^{\rm{T}}}\;{\rm{rad}}$
and
${\textbf{v}}(0) = {\left[ {0.05, - 0.03,0.04} \right]^{\rm{T}}}\;{\rm{rad/s}}$
. -
• Case 3:
${\textbf{q}}(0) = {\left[ { - 0.1, - 0.2,0.2} \right]^{\rm{T}}}\;{\rm{rad}}$
and
${\textbf{v}}(0) = {\left[ { - 0.01, - 0.02,0.03} \right]^{\rm{T}}}\;{\rm{rad/s}}$
. -
• Case 4:
${\textbf{q}}(0) = {\left[ {0.4, - 0.1, - 0.3} \right]^{\rm{T}}}\;{\rm{rad}}$
and
${\textbf{v}}(0) = {\left[ {0.03,0.04, - 0.01} \right]^{\rm{T}}}\;{\rm{rad/s}}$
.
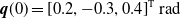
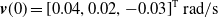


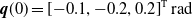
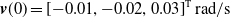


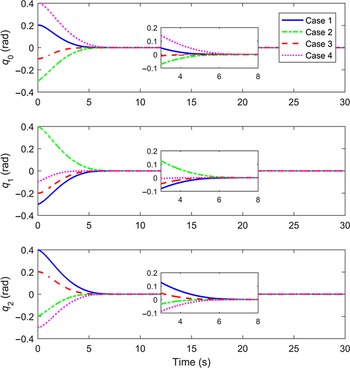
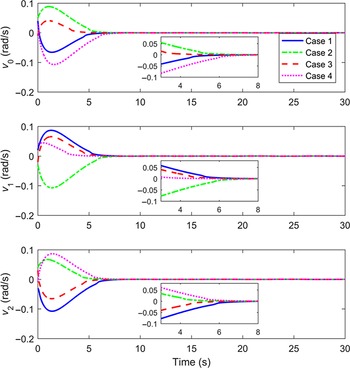
The simulation results for fixed-time convergence tests are provided in Figs. 8–10. It is clearly seen that the settling time of the proposed controller is nearly the same when the initial position and velocity of the space manipulator are chosen with the different values. The simulation results indicate that the proposed controller exhibits the fixed-time convergence capability, whose settling time is bounded and the upper bound of the settling time does not depend on the initial states of the space manipulator.
Time history of the position tracking.

Time history of the velocity tracking.

Time history of the control torques.

5. Conclusions
This article presents a novel robust fixed-time integrated control approach for the trajectory tracking of a free-flying rigid space manipulator perturbed by model uncertainties and external disturbances. The proposed robust fixed-time integrated controller is developed by integrating a nominal fixed-time PD-like controller with a fixed-time disturbance observer. It is strictly proved that the proposed controller can ensure the position and velocity tracking errors regulate to zero in fixed time even subject to lumped disturbance. Benefiting from the feedforward compensation, the proposed controller has the strong robustness and excellent disturbance attenuation capability. Lastly, simulations and comparisons demonstrate the effectiveness and advantages of the proposed control approach. Nonetheless, it should be pointed out that the proposed controller is unable to accommodate the actuator failures, which may frequently occur in practice. Inspired by [Reference Yue, Zhang, Dai, Ning and Yuan37–Reference Jia, Yuan, Chen and Fu40], our future research issue will focus on extending the proposed robust fixed-time integrated controller with the actuator tolerant capability.
Competing interests declaration
The authors declare none.